Underwater robotics
MATE ROV
I designed a modular claw hub and interchangeable claws for a student-built remotely operated underwater vehicle.
Read the technical design report (PDF)- My role
- Mechanical design, claw hub and claws
- CAD design time
- 60+ hours
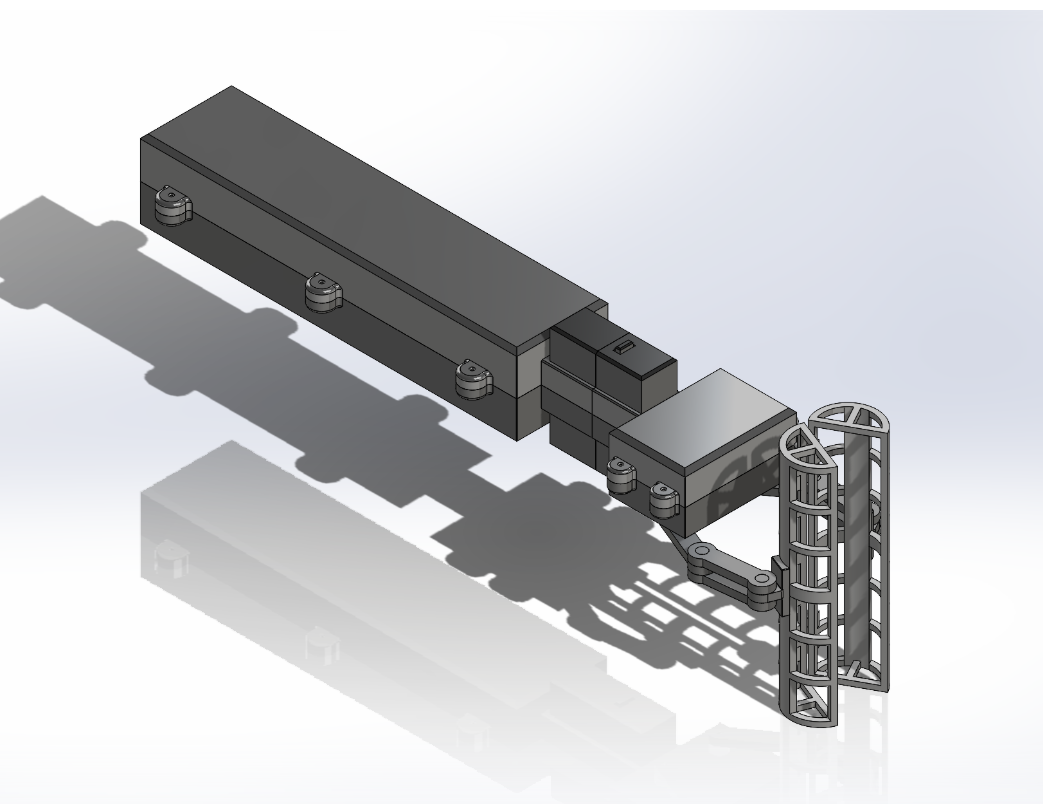
A common interface for multiple claws
I designed a common mounting hub so the team could swap claws for different tasks while keeping the same interface on the vehicle. My CAD work covered the hub and the claws that fit it.
The project included a 25-page team technical report.